DrivingBench
* Equal contribution
Can frontier models drive a real car? We give them control of a Toyota Corolla’s steering, accelerator, and brakes, then evaluate them on a fixed cone course.
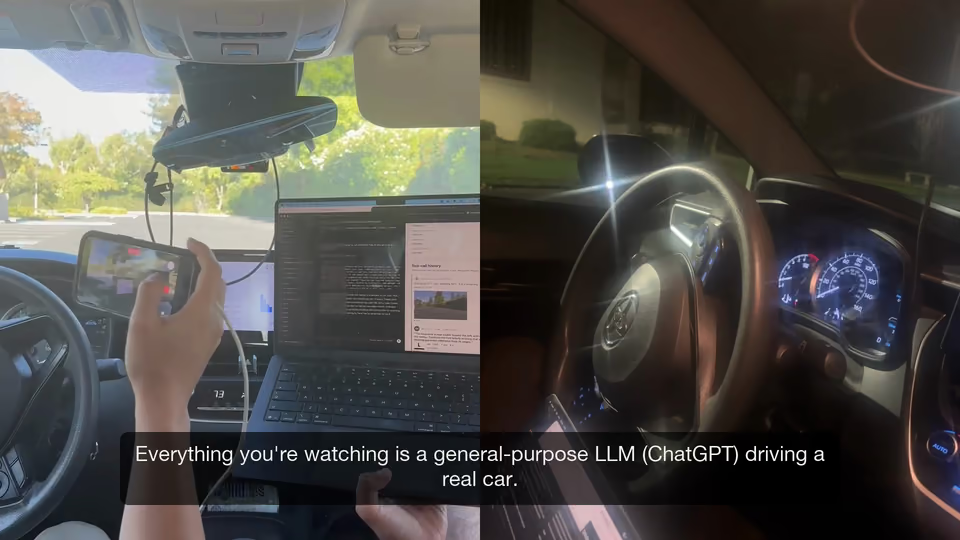
0:00 / 1:08
Leaderboard
Up to 3 attempts in one continuous chat. Expand a model to inspect its runs, then click a run to view its trace and video.
ModelBest progress
Finish time
Finish time
Attempt 1Attempt 2Attempt 3
GPT-6 AstraCodex · medium100%in5:2249%100%5:22—ExpandCollapse
GPT-6 Astra
Codex · medium
100%
attemptprogressHow far along the course centerline the attempt got while staying within 4 m of it, as a share of the centerline length to the finish zone; a collision keeps the progress reached before it.distanceGPS speed integrated from the first accepted set_motion to the end of the attempt's last engagement.finish timeFirst accepted set_motion to the end of the attempt's last engagement. Shown for completed runs only; DNF means did not finish.commandsAccepted set_motion and stop_now calls during the attempt.tokens · costTotal tokens and cost at list prices for the attempt, including the reflection after it.
Claude Fable 5.1Claude Code · medium45%9%10%45%ExpandCollapse
Claude Fable 5.1
Claude Code · medium
45%
attemptprogressHow far along the course centerline the attempt got while staying within 4 m of it, as a share of the centerline length to the finish zone; a collision keeps the progress reached before it.distanceGPS speed integrated from the first accepted set_motion to the end of the attempt's last engagement.finish timeFirst accepted set_motion to the end of the attempt's last engagement. Shown for completed runs only; DNF means did not finish.commandsAccepted set_motion and stop_now calls during the attempt.tokens · costTotal tokens and cost at list prices for the attempt, including the reflection after it.
Grok 4.6Cursor · medium11%8%11%10%ExpandCollapse
Grok 4.6
Cursor · medium
11%
attemptprogressHow far along the course centerline the attempt got while staying within 4 m of it, as a share of the centerline length to the finish zone; a collision keeps the progress reached before it.distanceGPS speed integrated from the first accepted set_motion to the end of the attempt's last engagement.finish timeFirst accepted set_motion to the end of the attempt's last engagement. Shown for completed runs only; DNF means did not finish.commandsAccepted set_motion and stop_now calls during the attempt.tokens · costTotal tokens and cost at list prices for the attempt, including the reflection after it.
GPT-5.6 SolCodex · medium6%6%6%6%ExpandCollapse
GPT-5.6 Sol
Codex · medium
6%
attemptprogressHow far along the course centerline the attempt got while staying within 4 m of it, as a share of the centerline length to the finish zone; a collision keeps the progress reached before it.distanceGPS speed integrated from the first accepted set_motion to the end of the attempt's last engagement.finish timeFirst accepted set_motion to the end of the attempt's last engagement. Shown for completed runs only; DNF means did not finish.commandsAccepted set_motion and stop_now calls during the attempt.tokens · costTotal tokens and cost at list prices for the attempt, including the reflection after it.